W200 Attachments
Bulkhead
The Warthog bulkhead is used to cover payloads and to add a second surface to which to attach more payloads.
Default
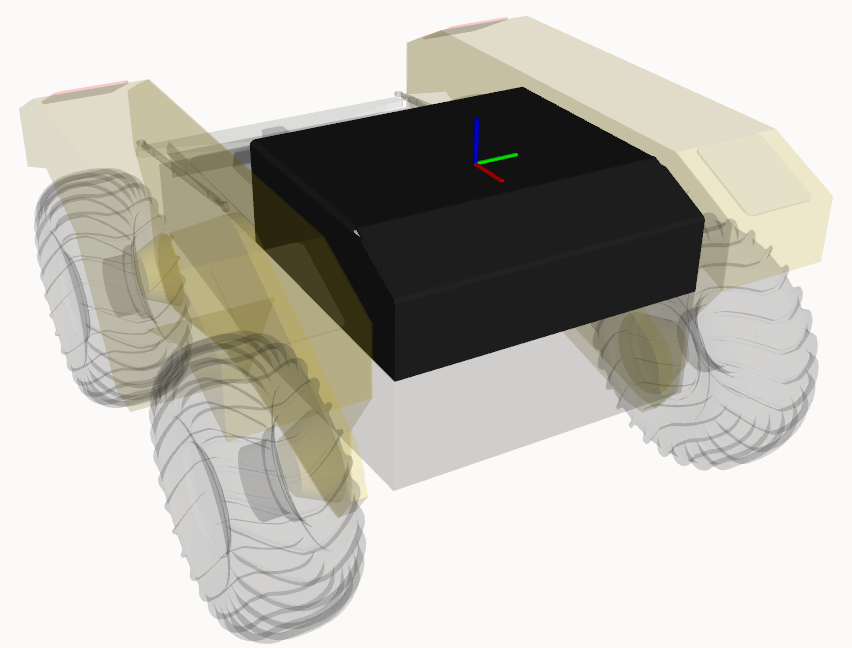 | |
Attach accessories to the bulkhead by setting the accessory's parent parameter to bulkhead_mount. The mount is displayed as an axis in the image above.
Arm Mount
 | |
Attach accessories to the arm plate mount by setting the accessory's parent parameter to arm_plate_mount. The mount is displayed as an axis in the image above.
Arm Mount
If instead of using the bulkhead to add an arm mount. We can add the arm mount independently using the following entry.
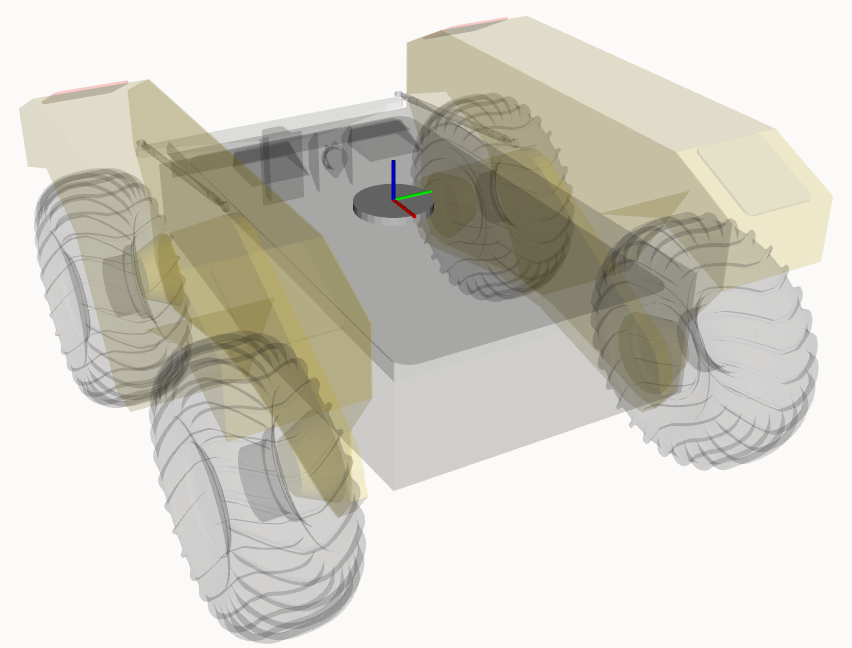 | |
Attach accessories to the arm plate mount by setting the accessory's parent parameter to arm_plate_mount. The mount is displayed as an axis in the image above.
Generator
 | |