A200 Attachments
Bumper
The A200 can have bumpers of a variable length. By setting the extension parameter, the bumper can be extended if required.
By default, we have two bumpers, on the front and rear of the robot.
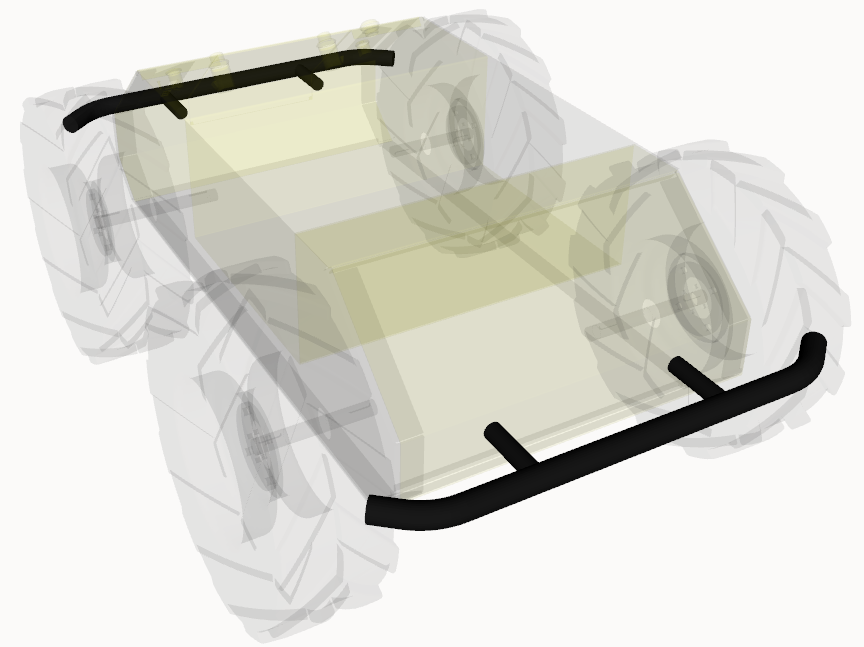 | |
The bumpers can be extended by setting the extension parameter.
Top Plate
The A200 has three types of top plates that modify the mounting surface of the robot.
Default
The default top plate is mounted atop a user rail that can be used to mount certain payload inside the chassis and right below the top plate.
 | |
Attach accessories to the top plate mounts by setting the accessory's parent parameter to either top_plate_rear_mount, top_plate_default_mount, or top_plate_front_mount. The mounts are displayed as axes in the image above.
Large
The large top plate does not have a user rail and is primarily used to mount larger payloads such as manipulators on the robot.
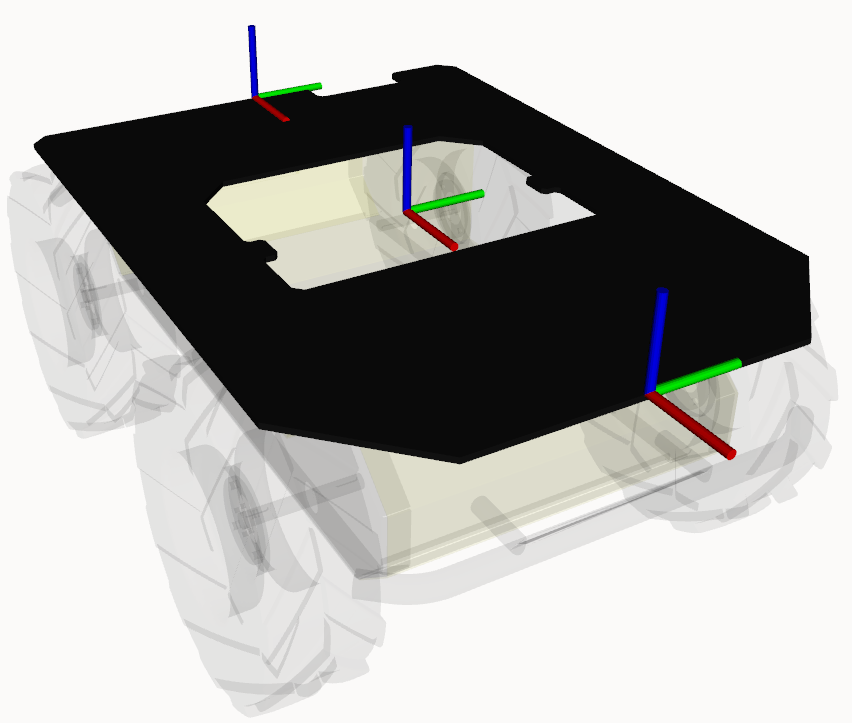 | |
Attach accessories to the top plate mounts by setting the accessory's parent parameter to either top_plate_rear_mount, top_plate_default_mount, or top_plate_front_mount. The mounts are displayed as axes in the image above.
Observer Backpack
The Observer backpack is a large enclosure with multiple mounting locations for additional sensors. It is used by the Husky A200 Observer.
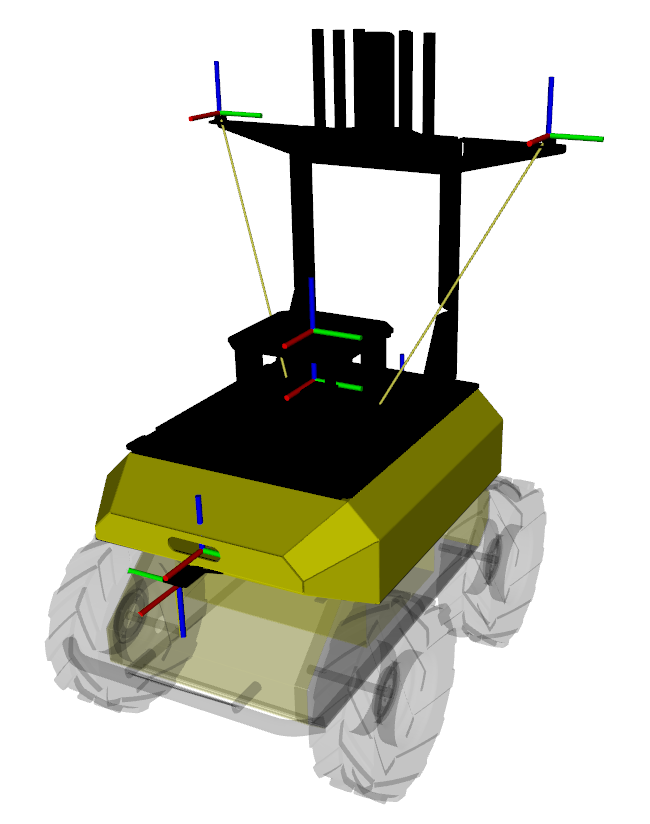 | |
The observer_backpack has the following mounts for attaching sensors, antennas, and other
accessories:
${name}_center_mount${name}_center_lidar_mount${name}_front_lidar_mount${name}_rear_lidar_mount${name}_front_realsense_mount${name}_rear_realsense_mount${name}_left_antenna_mount${name}_right_antenna_mount
PACS
The pacs top plate does not have a user rail. It has an opening to access the user bay within the chassis. It comes with the grid of mounting holes of the PACS™ 80mm x 80mm grid.
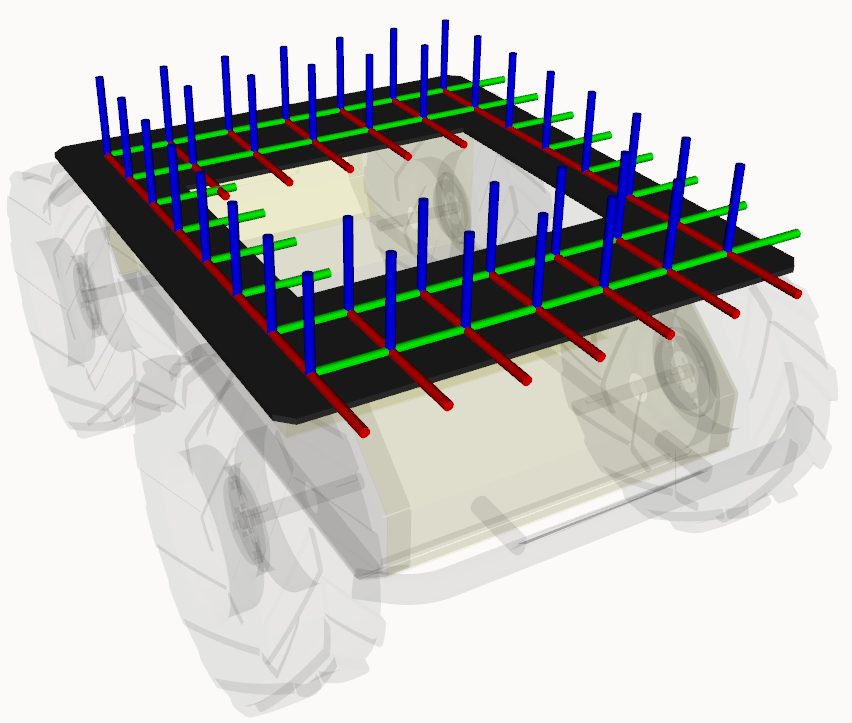 | |
Attach accessories to the top plate mounts by setting the accessory's parent parameter to one of the grid mounting locations displayed above. The grid mounting locations span from top_plate_mount_a1 to top_plate_mount_g8, where the front left-most location is the a1 mount and the bottom right-most location is the g8 mount. The letters correspond to the columns and the number to the rows.
Sensor Arch
The A200 has two types of sensor archs which are used to mount sensors from a vantage point.
Sensor Arch 300
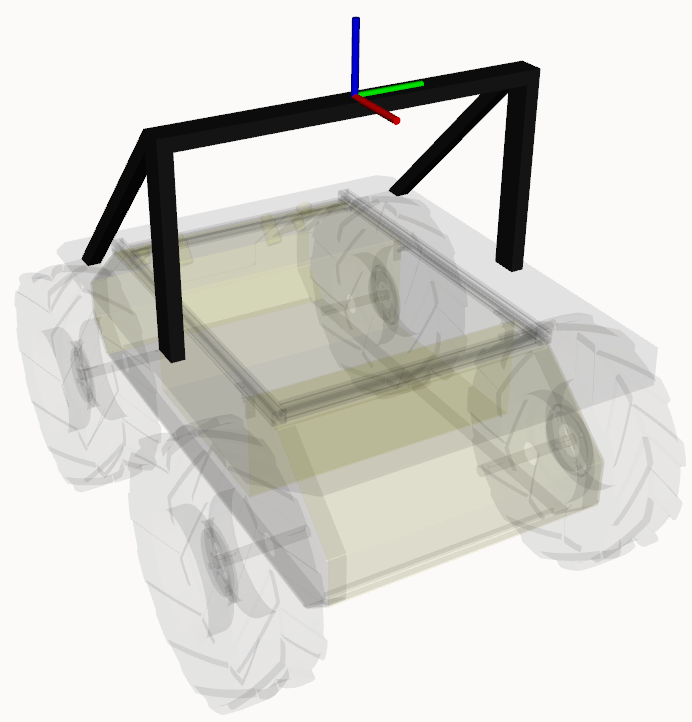 | |
Attach accessories to the sensor arch mount by setting the accessory's parent parameter to arch_sensor_mount.
Sensor Arch 510
 | |
Attach accessories to the sensor arch mount by setting the accessory's parent parameter to arch_sensor_mount.